ROBOTICS / MULTI-AGENT LEARNING
Project Argus.
One mission. More than one perspective. Exploring how a team of simulated drones can search together, using AirSim environments and multi-agent reinforcement learning.
Take it for a spin.
Replay a real simulator baseline, or explore an illustrative coordinated search with an adjustable fleet.
Opening the exhibit…
Loading a small, locally verified dataset.
FROM THE ORIGINAL SYSTEM
Behind the exhibit.
The trajectory file is captured directly from the installed AirSim Blocks simulator. The repaired path uses per-drone images, state, and collision readings, with an explicit camera RPC compatibility path. Perception remains a placeholder.
Baseline simulator execution is separate from trained-policy performance. No new policy training or validated victim detection is claimed.
Read the actual execution transcript ↗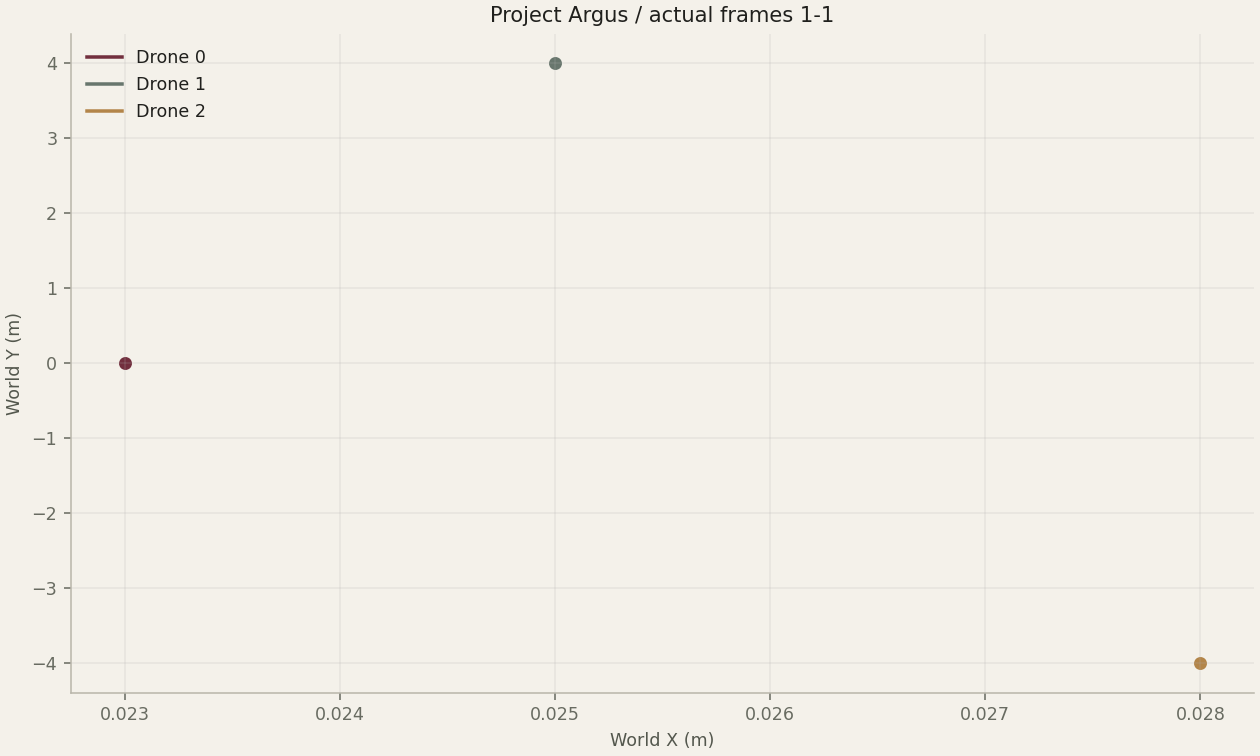
Three vehicle states in the installed Blocks environment, translated into a shared map using their configured spawn offsets.